Back to the workshopPHYSICAL EXPLORATION / Quadruped Robotics
Quadruped Robotics
Axelia - Quadruped Robot
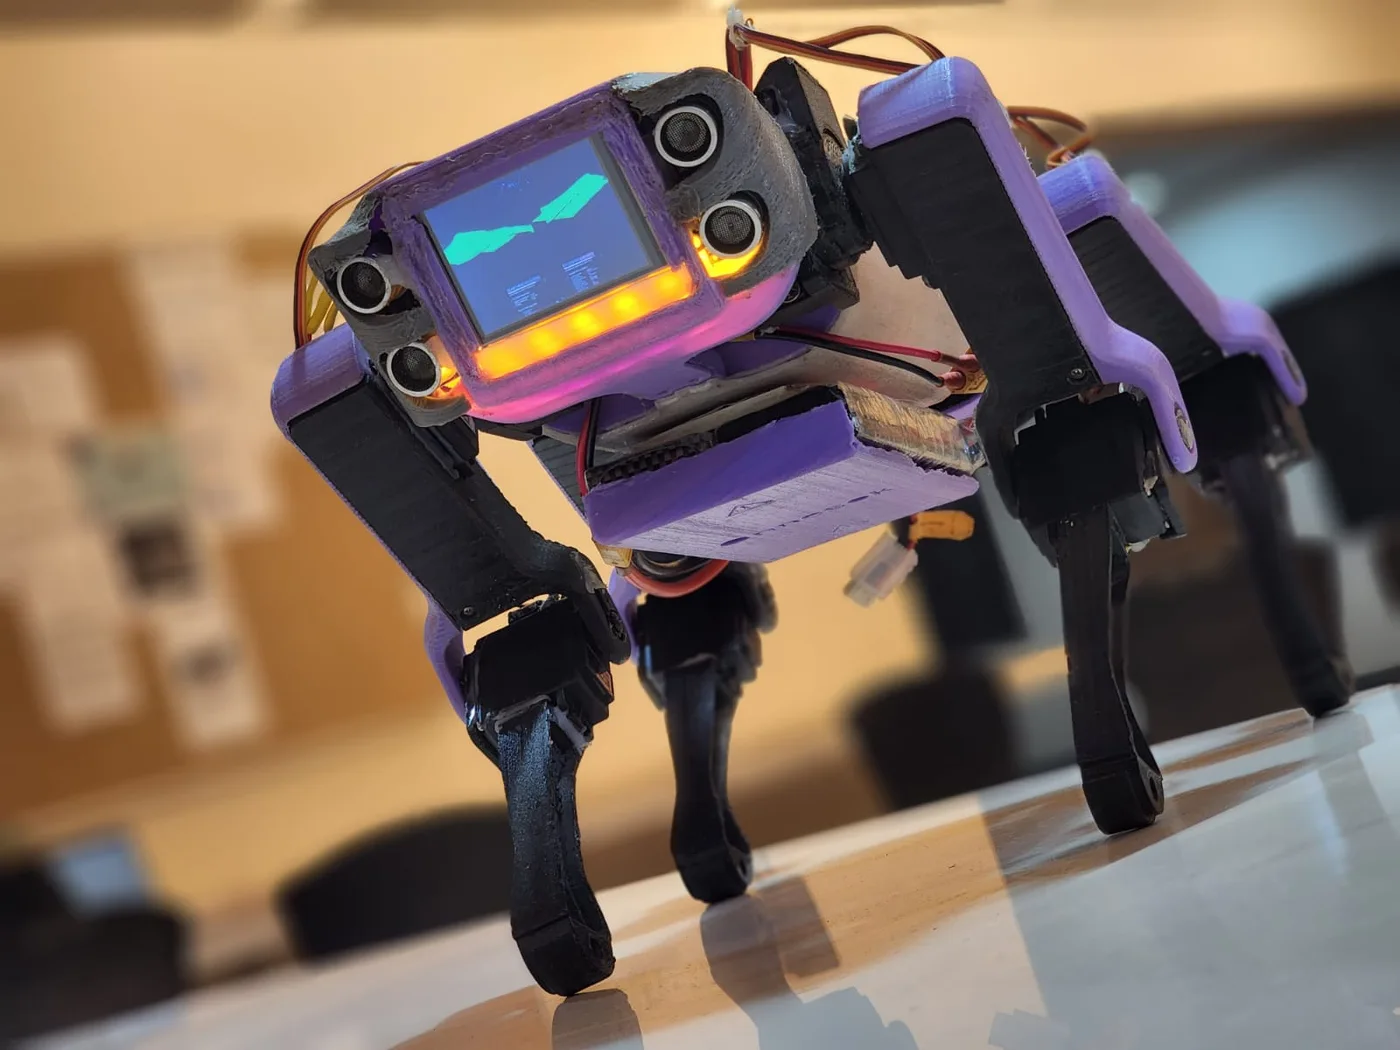
Four-legged robot with advanced terrain navigation and real-time environment mapping.
The idea.
Axelia is a quadruped robot built to traverse challenging terrains that wheeled robots cannot. Using ROS for motion planning and a SLAM-based mapping system, Axelia can build a map of its environment in real-time and autonomously navigate obstacles.
The gait control system implements multiple walking patterns (trot, crawl, bound) that it switches between based on terrain conditions detected by its depth camera and IMU sensors.
Inside the system.
- Dynamic gait switching (trot, crawl, bound)
- SLAM-based real-time environment mapping
- Depth camera obstacle avoidance
- ROS-based modular software architecture
- Autonomous terrain-adaptive navigation
A closer look.