Back to the workshopPHYSICAL EXPLORATION / AUV
AUV
Jol Torongo
Underwater robot for exploration and mapping with sonar and depth sensing.
The idea.
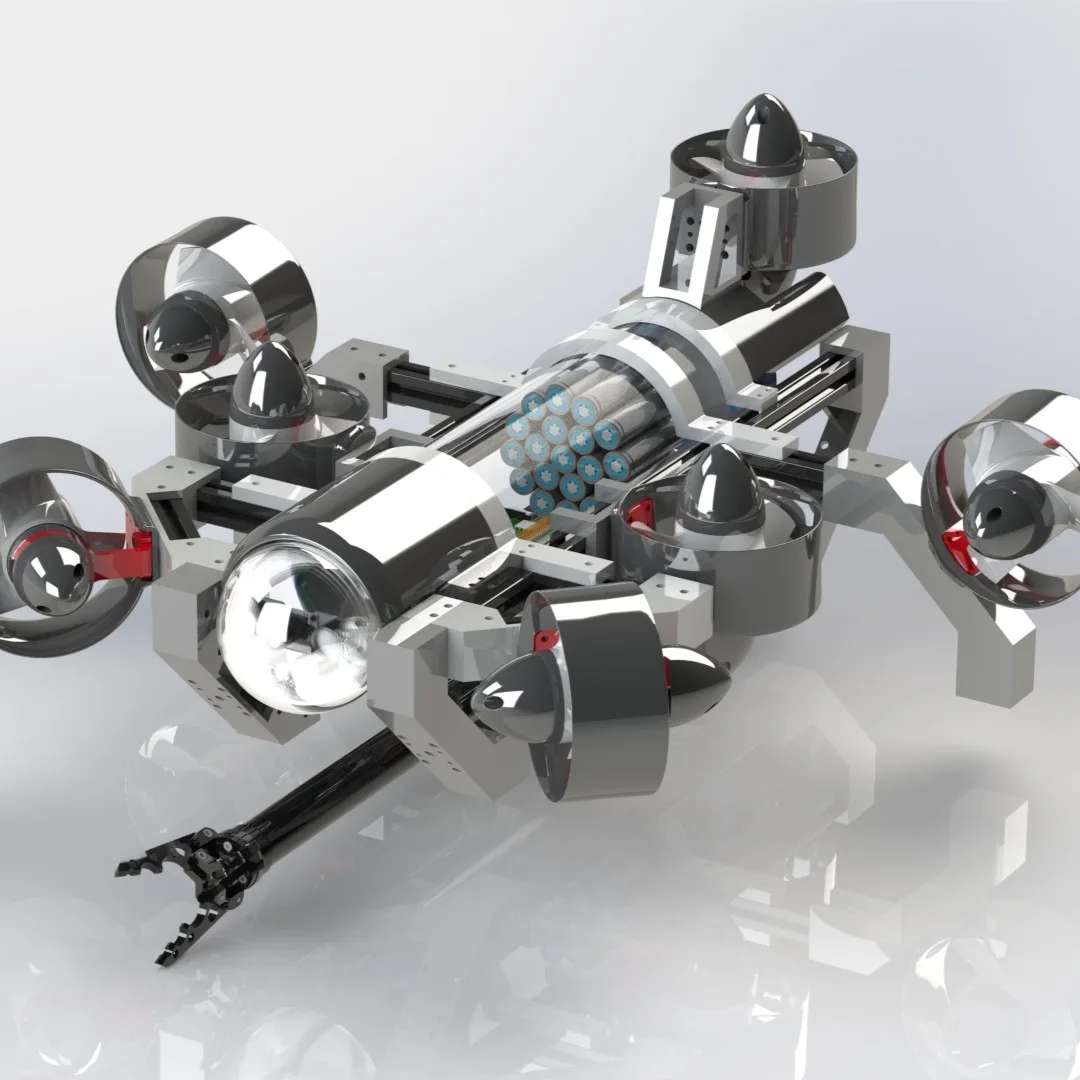
Jol Torongo is an Autonomous Underwater Vehicle (AUV) designed for shallow-water exploration and seabed mapping. It uses a sonar system paired with depth sensors to create 2D maps of underwater environments, with a camera transmitting live footage to a surface operator.
The waterproofed chassis was designed in CAD and manufactured in-house, with a custom thruster configuration for 3-axis control underwater.
Inside the system.
- Sonar-based underwater mapping
- Live camera feed to surface operator
- Depth sensor for depth-hold mode
- 3-axis thruster control system
- Custom waterproofed CAD chassis
A closer look.