Back to the workshopPHYSICAL EXPLORATION / Humanoid Robot
Humanoid Robot
Pixi v1.0
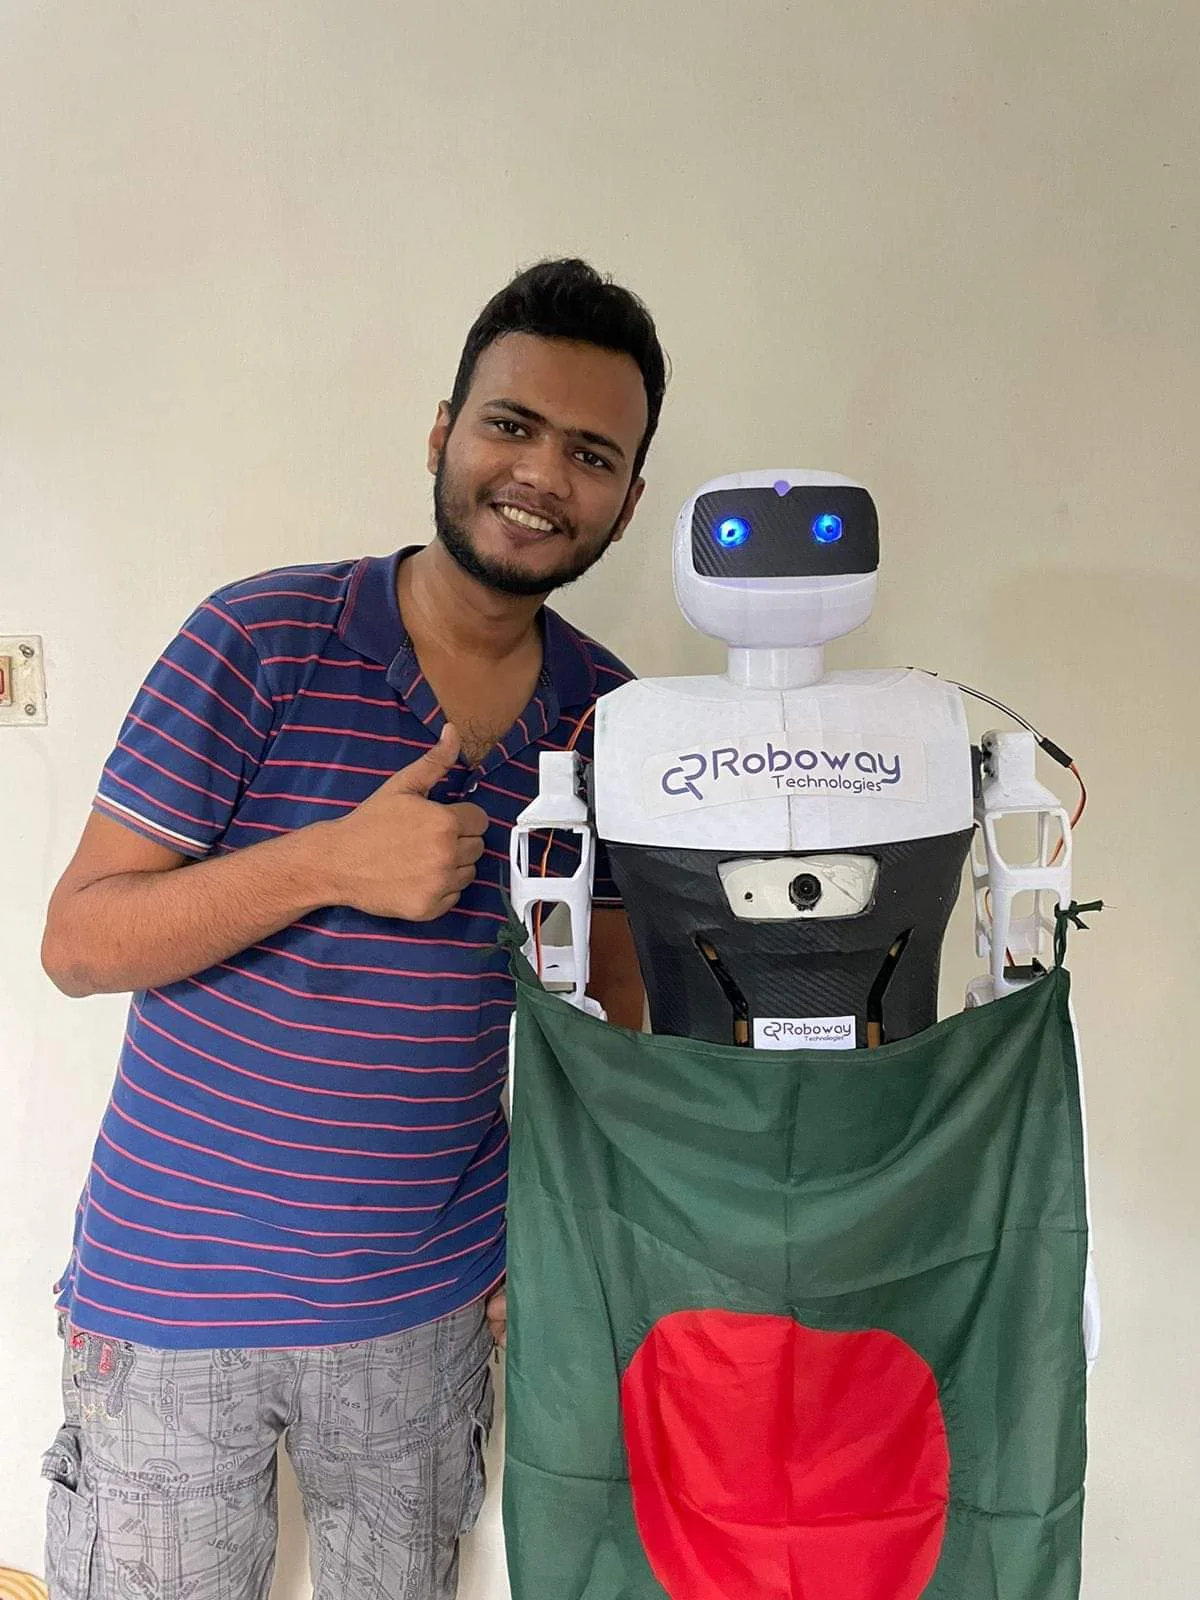
First iteration of the humanoid robot project with basic movement and sensor integration.
The idea.
Pixi v1.0 was the foundation of the humanoid robot series. It established the core mechanical frame and servo control architecture that all subsequent versions built upon. This iteration focused on achieving stable bipedal walking and basic arm movement.
Built entirely from scratch with 3D printed parts and off-the-shelf servo motors, Pixi v1 proved the feasibility of a low-cost humanoid platform.
Inside the system.
- Bipedal walking prototype
- Basic servo arm control
- Sensor-based obstacle detection
- Fully 3D-printed custom frame
A closer look.